The Orchard Leap A significant increase in difficulty
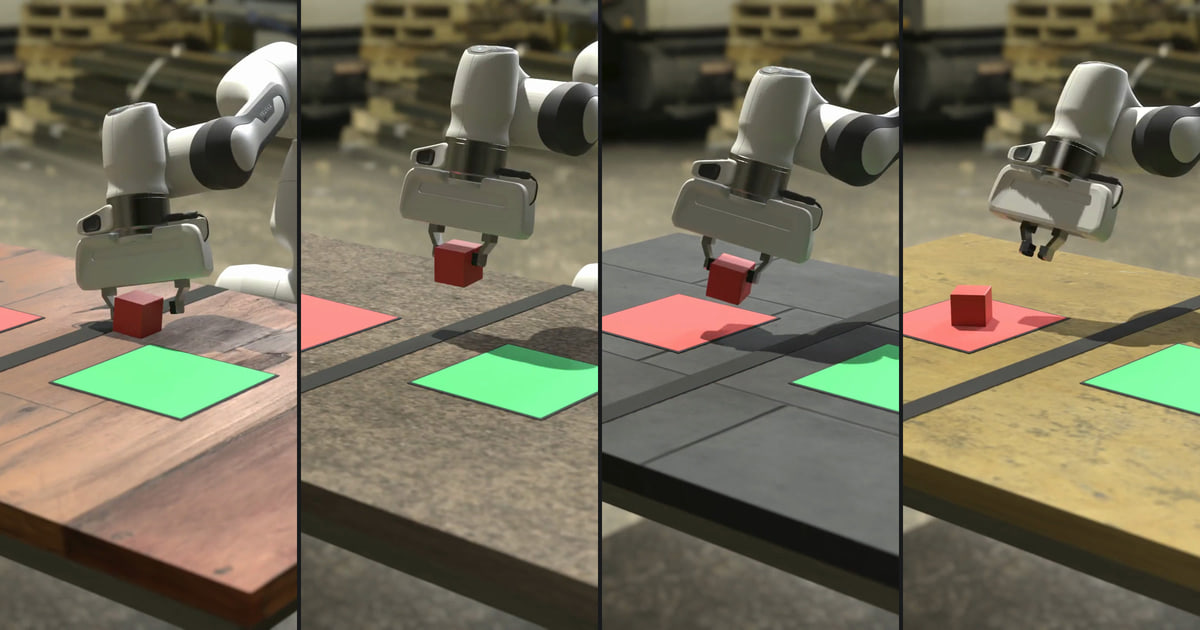
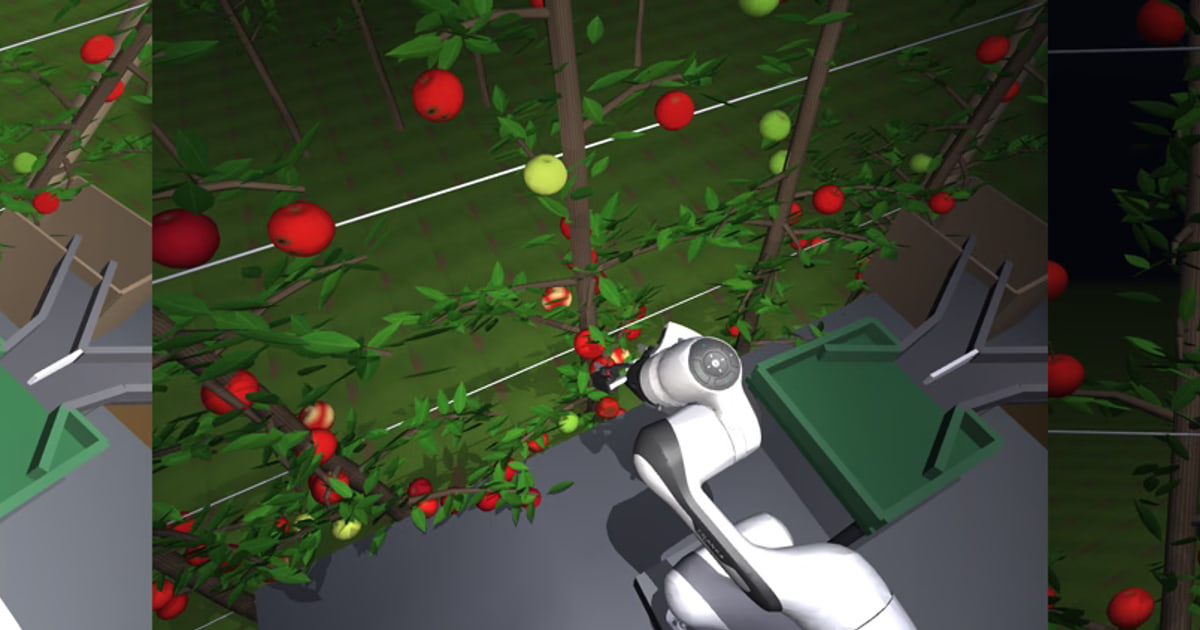
Taking the Mamba-3 and Liquid CfC robot out of the tabletop sandbox and into a moving orchard platform in MuJoCo.
Explore my latest projects, research, and technical guides on robotics, control systems, and automation.
Taking the Mamba-3 and Liquid CfC robot out of the tabletop sandbox and into a moving orchard platform in MuJoCo.
Continuing to improve the Mamba + LNN powered Franka Emika robot arm with parallelized cloud training, improved models, and closing the sim-to-real gap.
A systems view of continuous robot reinforcement learning: why control splits across a 20 Hz policy loop and a 500 Hz PD loop, how GAE trades bias for variance, the truncation bug that quietly biases every late-episode advantage, what the PPO clip does and does not constrain, and which metrics to read when a run goes bad.
Designing a multi-rate vision-based pick-and-place policy for a 7-DOF Franka Panda arm from first principles: 10 Hz Mamba-3 SSM Cortex, 50 Hz Liquid CfC Brainstem, SpatialSoftmax, and DLS Inverse Kinematics.
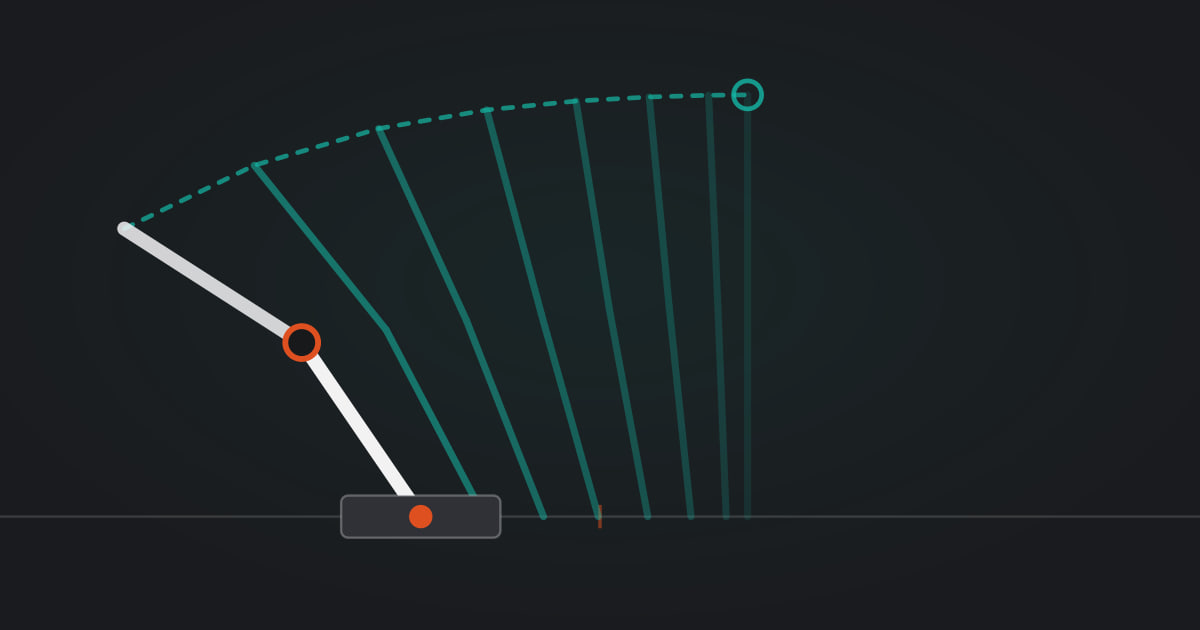
Ditch the pre-computation phase, the controller plans it all live, up to 200 times a second, in the browser. Learn how prediction controllers work.
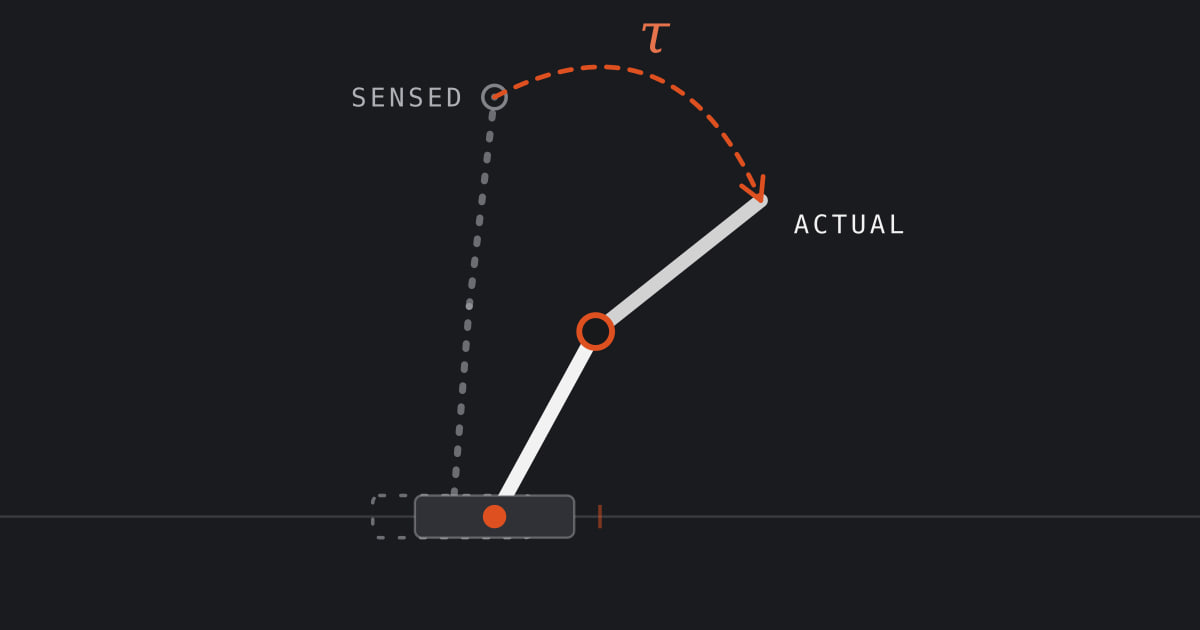
The same controller, this time bringing a bit of the real world into the sim. Find out what breaks and how to fix it.
One motor against three degrees of freedom. I cover trajectory optimization, LQR, and the handoff between them. Everything running live in the browser.